Robotic sampling
An articulated arm for sample-handling experiments, with a proposed on-board analysis laboratory.
Robotic sampling, onboard analysis and autonomous navigation for a proposed lunar exploration platform.
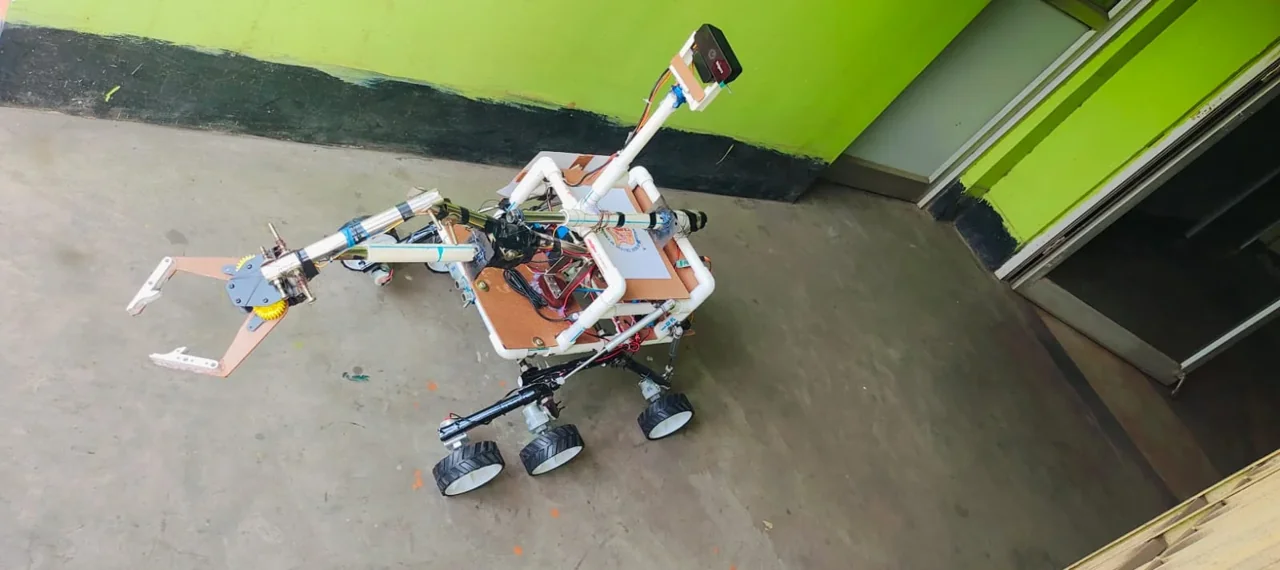
Talisha Space describes Lunar Rover V-1 as a research platform intended to collect samples, examine lunar minerals and investigate water-ice indicators. The wider concept includes transmitting sensor results through satellite communications and investigating whether more onsite analysis could reduce the need to return every sample to Earth.
The rover pictured is a terrestrial engineering prototype; no lunar operation, resource detection or space-qualified test is claimed.
An articulated arm for sample-handling experiments, with a proposed on-board analysis laboratory.
Research into assisted and autonomous rover navigation for terrain awareness and movement.
A solar-powered design concept with satellite-data transmission objectives.
Concept studies for identifying mineral signatures and potential water-ice indicators.
The project sits alongside Talisha Space rover research, Lunar Rover V-1 work and student lunar-rover challenge participation. Some activities have been connected to engineering initiatives at BCET and AICT Durgapur. These references describe research background; they are not formal ISRO mission affiliations.
The rover demonstration begins at 05:25 and requests muted playback when this video enters your screen. Video controls remain available.